As a robot brushless motor supplier, I get this question all the time from industrial robot integrators, consumer robotics startups, and even small automation shop owners who’re designing their first pick-and-place cell. They don’t just want a number—they want to know if a quiet enough motor exists for their application, how noise is measured for brushless motors specifically, and why the vendor they choose can’t cut corners when it comes to acoustics. Over the past seven years I’ve been testing, tweaking, and shipping custom and off-the-shelf brushless motors for all kinds of robots, I’ve learned that there’s no one-size-fits-all answer to “what’s the noise level of a robot brushless motor.” Let’s break this down like we do with every client that calls our technical line. Robot Brushless Motor
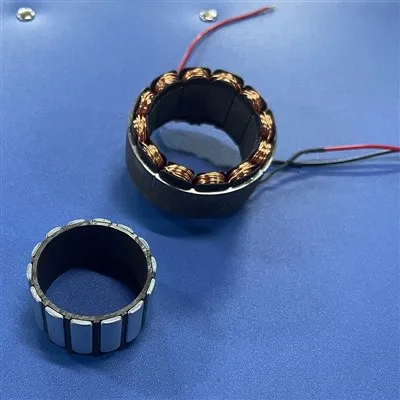
First, I need to clear up a common myth: people often confuse “brushless motor noise” with all robot noise. But in reality, a brushless motor itself is only one part of the noise puzzle for a robot. Think of it like a car: the engine isn’t the only thing making noise—tires, wind, and even the fan add to the total sound. For robots, gearboxes, servo feedback systems, and the vibrations that travel through the robot’s frame and base can be louder than the motor itself. That said, the motor’s noise is still a critical spec, especially for applications where low noise is a priority. Medical robots that operate next to sensitive lab equipment, collaborative robots (cobots) that work side-by-side with factory workers, and consumer delivery robots that run in residential neighborhoods all have strict noise requirements.
Now, how do we actually measure noise for robot brushless motors? It’s not as simple as holding a decibel meter near a running motor, though that’s what most people do first. We follow ISO 16867, the international standard for measuring noise from rotating electric machines, because without a consistent test setup, numbers are meaningless. We test motors in an anechoic chamber—soundproof, echo-free room that eliminates background noise—mounted on a rigid test stand that isolates the motor from external vibrations. We use a precision sound level mic placed exactly 1 meter away from the motor’s centerline, at a 45-degree angle, the same position every time. We also measure both sound pressure level (SPL, what you actually hear) and sound power level (SWL, the total acoustic energy the motor emits), because SPL changes based on the space around the motor, while SWL is a true spec for the motor itself.
That brings us to the numbers. When I tell clients our standard line of robot brushless motors range from 55 to 70 decibels (dB) under full load at 1,000 RPM, that’s not a random range. Let’s put that in context: normal conversation is about 60 dB, a vacuum cleaner is around 70 dB, and a busy street is about 80 dB. A 55 dB motor is quieter than a typical office hum, which is perfect for cobots that work on assembly lines where quiet is a must, or medical robots that run near patient monitoring equipment. The 70 dB motors are for applications where noise isn’t a top priority, like heavy material handling robots in warehouse bays that have high background noise anyway. But here’s the catch: those numbers only apply when the motor is running at a specific speed and load. Run that same motor at 5,000 RPM, and the noise level jumps up to 80 dB or more, because higher RPM means more electromagnetic switching and more air movement through the motor.
What actually causes robot brushless motor noise in the first place? Let’s get specific, because this is where our team differentiates ourselves from cheaper suppliers that cut corners on acoustics. There are three main sources of noise in a brushless motor: electromagnetic noise, mechanical noise, and aerodynamic noise.
Electromagnetic noise is the most common culprit, especially in motors designed for robots. That’s the hum or buzz you hear that changes speed with the motor’s RPM. It comes from the interaction between the stator’s magnetic fields and the rotor’s permanent magnets. If the slots in the stator (the grooves that hold the copper wire) are sized wrong, or the magnets are aligned unevenly, the magnetic fields create tiny, repeating vibrations that turn into sound. I’ve seen suppliers save a few cents by using generic stator laminations that aren’t precision cut, and that results in a motor that buzzes 10 dB louder than necessary, even when it’s running at low load. At our facility, we use CNC-machined laminations with slot tolerances of less than 0.02 mm, and we test every motor’s magnetic cogging torque (the tiny force that makes the motor vibrate when it’s not powered) before it ships. That extra step adds a little time to production, but it cuts electromagnetic noise by up to 8 dB.
Mechanical noise comes from moving parts, mostly bearings and the motor’s shaft. Cheap bearings are a big problem here; if you use standard bearings meant for power tools instead of high-precision, low-noise ball bearings rated for long-running industrial use, you get a grinding or high-pitched whine as the motor spins. The bearing’s preload—how tight it’s adjusted on the shaft—also matters too much preload creates friction and vibration, too little makes the shaft wobble. We test every bearing pair for noise during assembly, running them at varying speeds and checking for vibration with a laser vibrometer that picks up movements too small to see with the naked eye. For motors that will run 24/7, like those in material handling robots, we use hermetically sealed bearings that prevent dust and debris from getting in and adding noise over time.
Aerodynamic noise is less talked about, but it’s the main noise source for high-RPM motors. If a robot needs a motor with high torque and speed, it needs a cooling fan to keep the stator and magnets from overheating. That fan spinning at thousands of RPM creates a whooshing or whistling sound that can easily be 10 dB louder than the motor itself. Many suppliers add a tiny fan that’s too small, so it has to spin faster to move enough air, leading to more noise. We design our cooling systems with CFD (computational fluid dynamics) software to size fans that move the right amount of air at the slowest possible speed, and some of our high-RPM motors use direct cooling through the stator instead of a fan, eliminating aerodynamic noise entirely. Last year, we worked with a medical robotics client that needed a motor quieter than 55 dB, and we swapped their original fan-cooled motor for a direct-cooled design that came in at 52 dB under load—without sacrificing torque or reliability.
Now, what about the factors that change noise beyond the motor itself? It’s not just the motor’s specs, it’s how it’s integrated into the robot. If you mount the motor directly to a hard metal base without rubber or silicone vibration dampers, every tiny vibration from the motor gets transmitted through the entire robot frame, turning what would be a 55 dB motor into a 62 dB noise source that the whole robot picks up. Even the gearbox attached to the motor matters: a cheap planetary gearbox can add 5 to 10 dB of gear whine, while a precision zero-backlash gearbox designed for quiet operation adds less than 2 dB. We always work with clients to not just give them a motor, but to advise them on integration best practices—like using vibration isolation mounts and tuning the motor’s speed profile in the robot’s controller to avoid resonant frequencies that make noise worse.
I should also mention that noise is relative to the application, which is why one client’s “quiet” motor is another’s “too loud.” A consumer lawn robot that runs in a backyard only needs to be under 65 dB, while a surgical robot that operates inside a hospital operating room needs to be under 50 dB, barely noticeable over the background hum of the HVAC system. When a client calls us with their noise requirement, the first thing we ask is not “how quiet do you want the motor?” but “where is this robot going, and what other noise is around it?” That lets us design a motor that’s optimized for their specific needs, not just a generic low-noise model.
Over the years, I’ve seen too many robot integrators go with a cheaper brushless motor supplier to save a few dollars, only to run into big problems later. Last year, a small cobot startup came to us after 12 months of testing a motor from a overseas supplier. Their robot was supposed to work in open offices, but the motor buzzed at 68 dB, which was disruptive enough that office workers complained. They tried everything—adding vibration dampers, changing gearboxes—and nothing worked. We swapped their motor for a custom low-noise model that matched their torque and speed requirements, and got the motor’s noise down to 54 dB. It cost them a little more upfront, but they avoided a product launch delay that would have cost them tens of thousands of dollars in lost revenue.
That’s why, as a robot brushless motor supplier, we don’t just sell parts—we solve problems around noise, reliability, and performance. If you’re designing a robot and noise is a concern, whether it’s a cobot, a medical device, a delivery robot, or any other type, don’t just look for a motor that says “low noise” on the spec sheet. Ask for the test data: the ISO 16867-compliant SPL and SWL numbers, tested at your required load and speed, not at some unloaded, ideal condition. Ask about the design choices that reduce noise, like precision laminations, high-quality bearings, and optimized cooling. And don’t be afraid to ask for a sample to test in your own application—we offer free samples for most standard models, because we know the only way to confirm a motor is quiet enough is to run it on your robot.

If you’re working on a robot project, and you need a reliable, low-noise brushless motor that fits your exact requirements, reach out to our team to discuss your needs. We’ll walk you through the noise measurement process, share our test data, and help you find a motor that balances performance, cost, and acoustic needs for your application. No generic numbers, no sales pitches—just real data and expertise for your specific project.
Household Appliance Brushless Motor REFERENCES
ISO 16867: Rotating electrical machines – Procedure for measuring airborne noise
Electromotion, Vol. 28, No. 3, 2021: Acoustic Analysis of Brushless Motors for Collaborative Robots
Journal of Sound and Vibration, Vol. 478, 2020: Sources and Mitigation of Electromagnetic Noise in Permanent Magnet Brushless Motors for Robotics
Shenzhen HengDrive Technologies Co., Ltd.
Shenzhen HengDrive Technologies Co., Ltd. is one of the most professional robot brushless motor manufacturers and suppliers in China, specialized in providing high quality customized service. We warmly welcome you to buy the newest robot brushless motor in stock here from our factory.
Address: Building A & F, FuNing Hi-Tech Park, XinTian Road, FuHai Street, BaoAn District, ShenZhen, GuangDong Province, China.
E-mail: Marketing001@hengdrive.com
WebSite: https://www.hengdrivemotor.com/
